Benjamin’s assembled independent AMR platform

Robotics / Independent development

From a chassis
to a system.

My autonomous mobile robot development platform.
Assembled and joystick-controlled. Advanced autonomy in progress.

Explore the platform ↗

Autonomous Mobile Robot
Development Platform.

I assembled a 24V two-wheel differential-drive robot as a reusable base for development. An early application idea evolved into a platform for different sensors, perception models, and mechanisms.

The physical robot exists and can be driven. Current work connects power, geared motors, encoders, embedded control, Jetson compute, and ROS 2 communication.

Assembled · joystick control
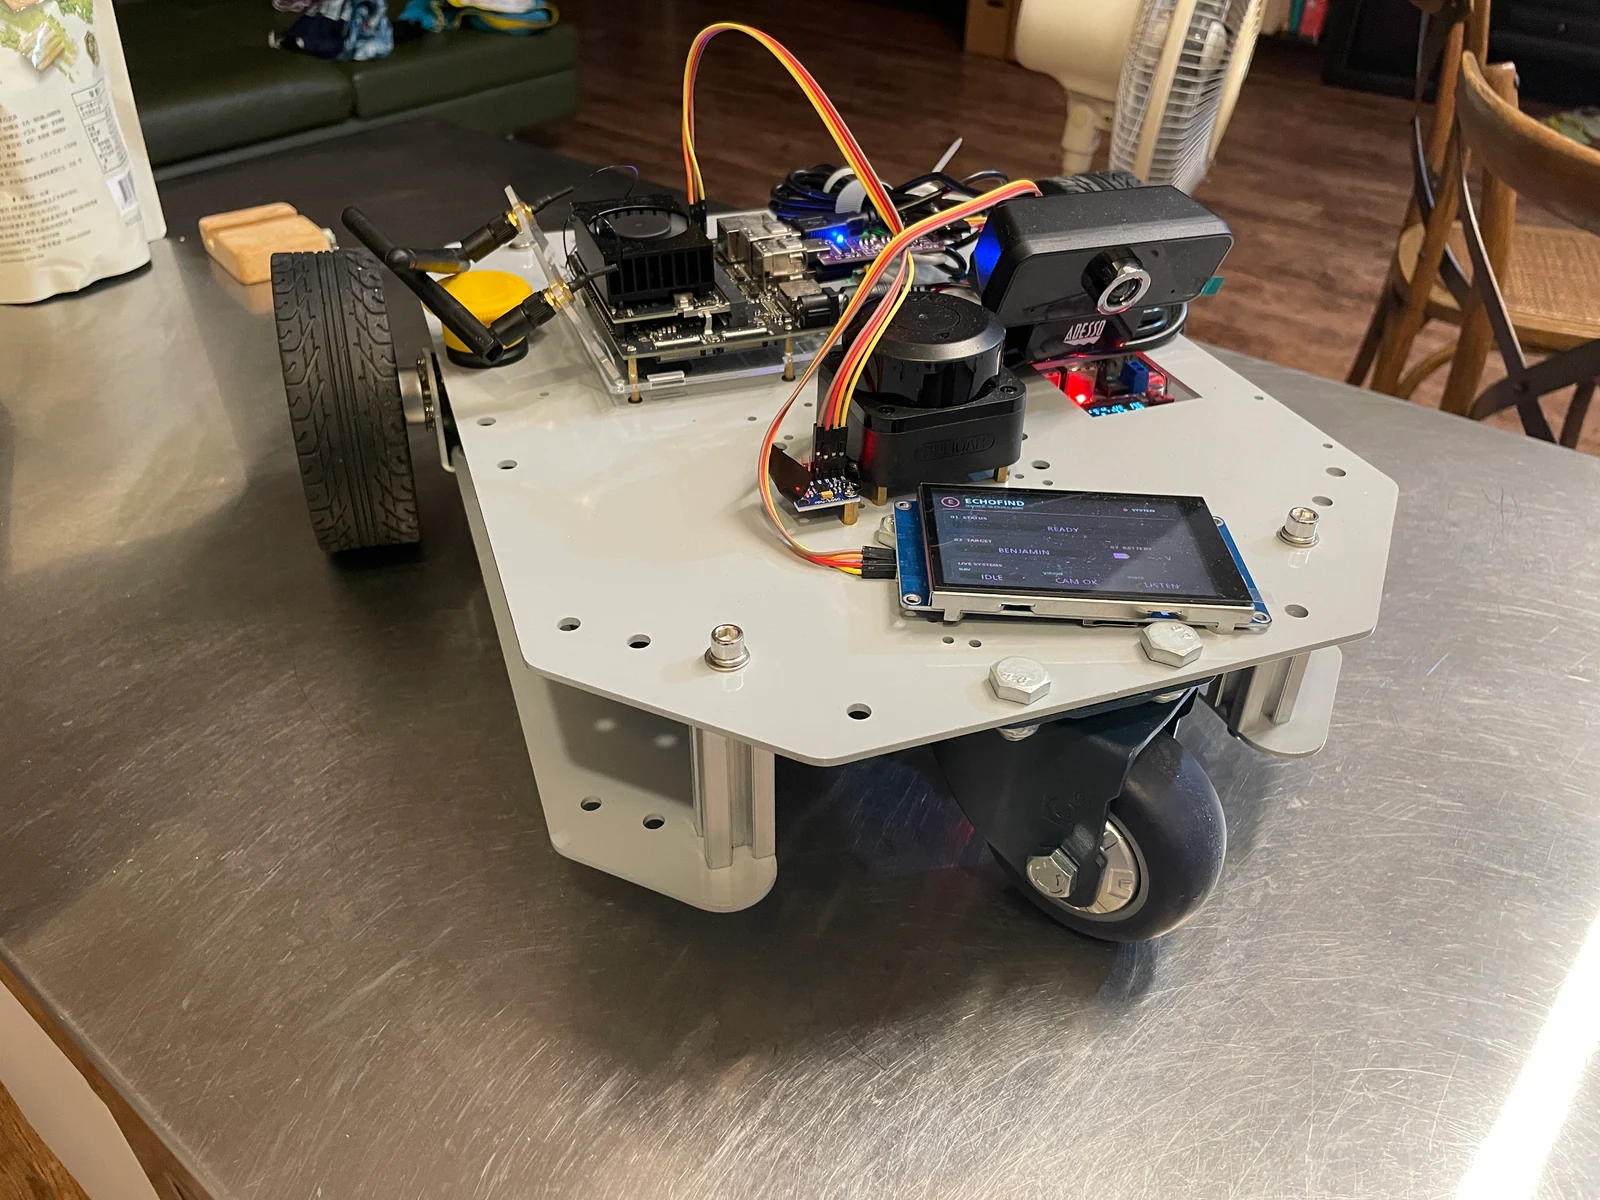
Front three-quarter view of Benjamin’s assembled robot, showing wheels, electronics and base
The assembled platform · Original workshop setting
AMR / Conceptual architecture24V
AMR logical system architecture Two-wheel differential drive with motor encoders, STM32 control, Jetson compute and ROS 2. Dashed LiDAR, camera and navigation components remain in development. This is a functional schematic, not a CAD drawing. DIFFERENTIAL DRIVE 24V / 60W MOTOR AB encoder · left 24V / 60W MOTOR AB encoder · right STM32 Low-level motor control JETSON ORIN NANO SUPER 8GB · Ubuntu · ROS 2 Humble LiDAR CAMERA / YOLO SLAM → LOCALIZATION → NAV2
Assembled / current stackUnder development

System architecture — conceptual. Not derived from CAD.

Hardware.
Software.
One platform.

Drivetrain
Two-wheel differential drive · 24V / 60W geared motors · AB encoders
Control
STM32 · motor and encoder integration · proportional speed control · joystick / joy commands
Compute
Jetson Orin Nano Super 8GB · Ubuntu · ROS 2 Humble
In progress
LiDAR · camera / YOLO · SLAM · localization · Nav2 · obstacle avoidance · autonomous navigation
Current boundaryThe assembled base can be driven. Advanced perception and autonomy are still being integrated and tested.
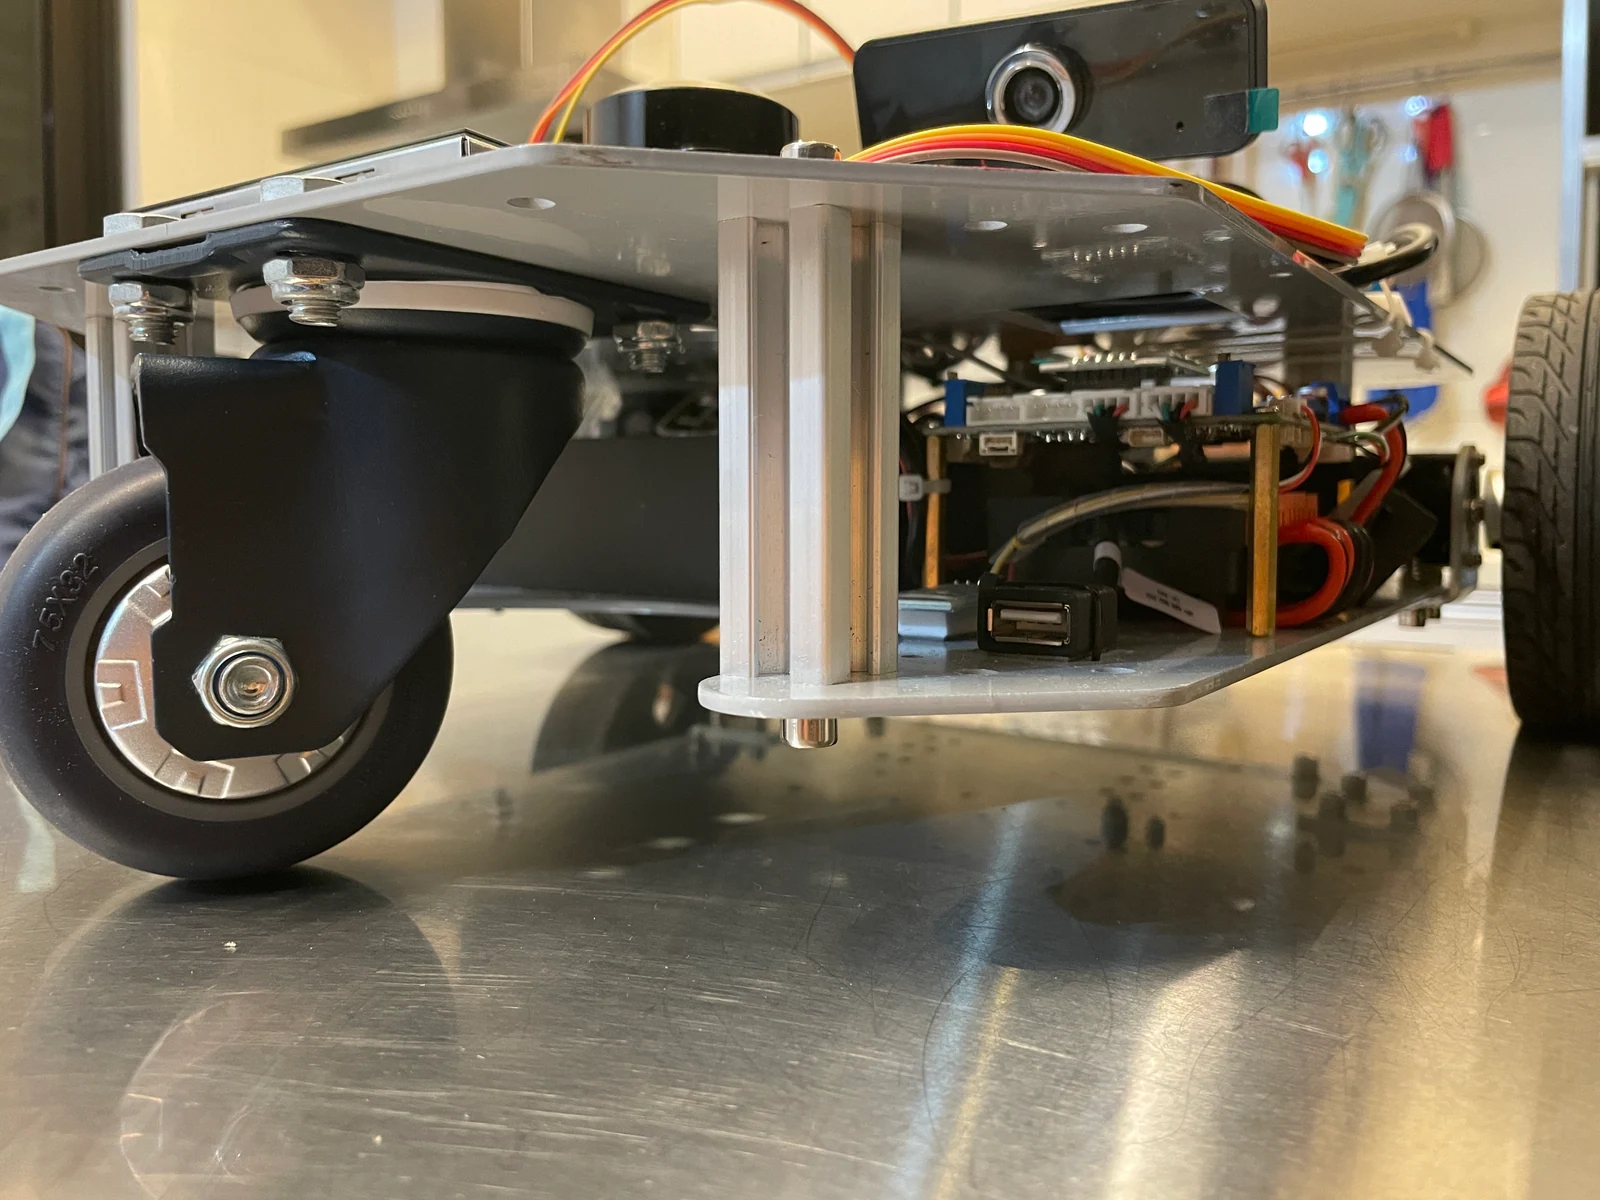
Low-angle view of the robot chassis, front caster and lower electronics
Under the base · Chassis and lower layer
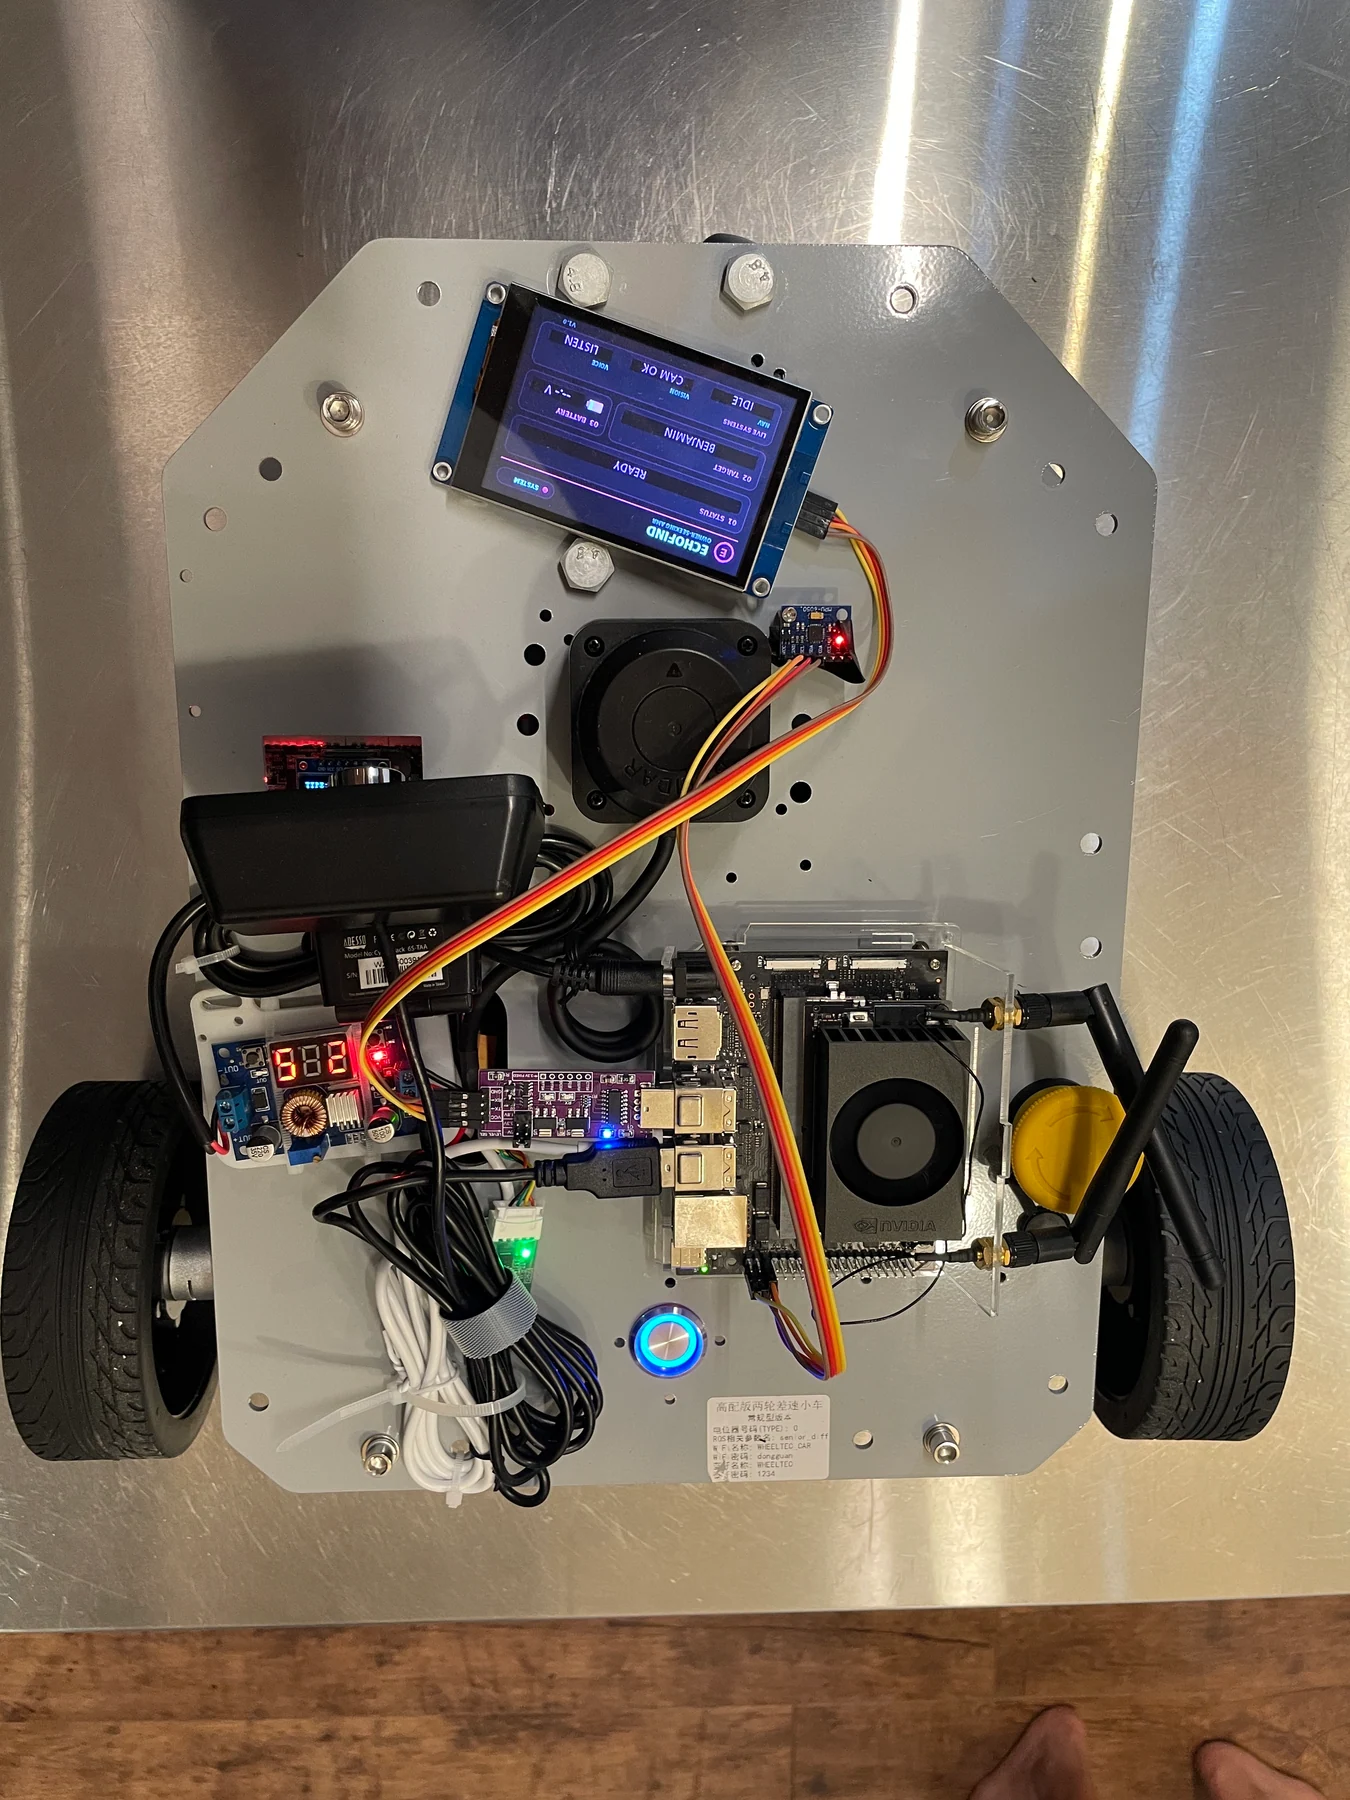
Top view of the powered robot with controller wiring, compute board and display
Power and wiring · Top view
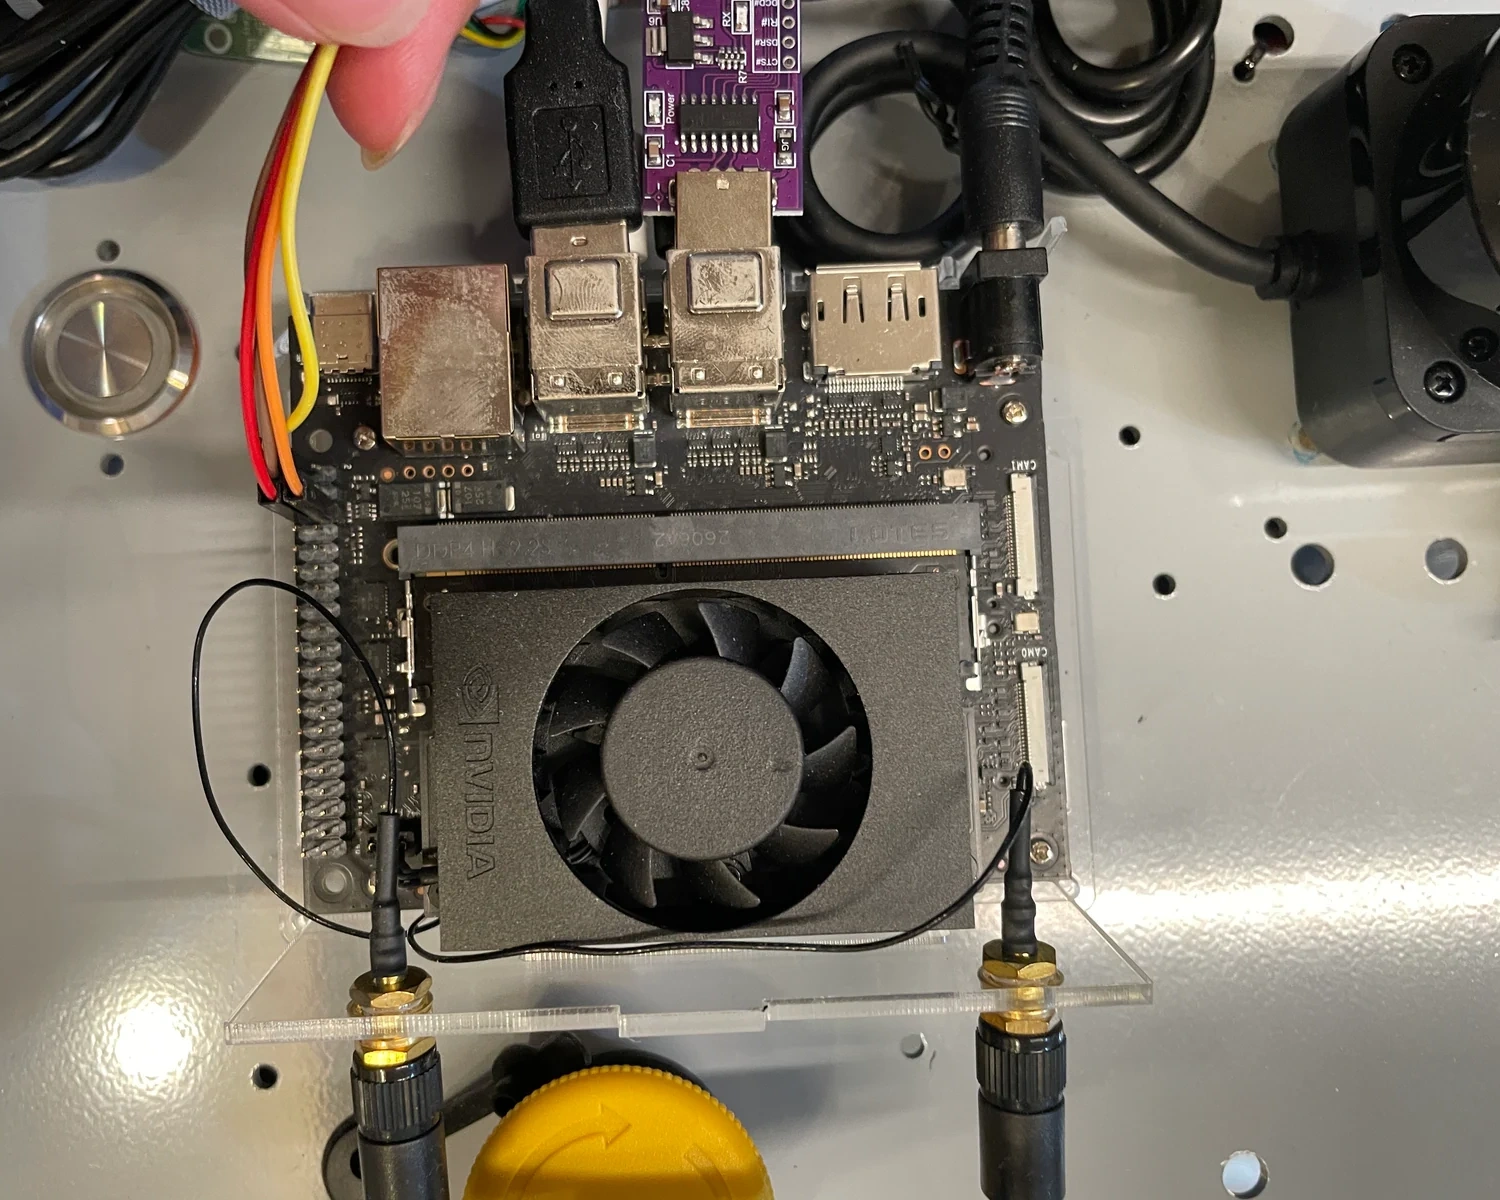
Close view of the mounted Jetson board, fan and connectors
Compute detail · Jetson shown; STM32 detail still needed
Evidence / pendingLiDAR integrationFull frame · no crop
LiDAR integrationImage to be added
Evidence / pendingROS / RVizFull frame · no crop
ROS / RVizImage to be added
Video / pendingMovement testShort demo · controls enabled
Movement testVideo to be added